

ADAS-TO longitudinal — closing case-control windows (n = 5090)
Companion subset of the ADAS-TO dataset for longitudinal (car-following)
take-over modeling. This is a case-control set, not 5090
takeovers: 2293 takeover cases (arm T) and 2797 non-takeover closing
controls (arm Q) drawn from the same drives.
Examples
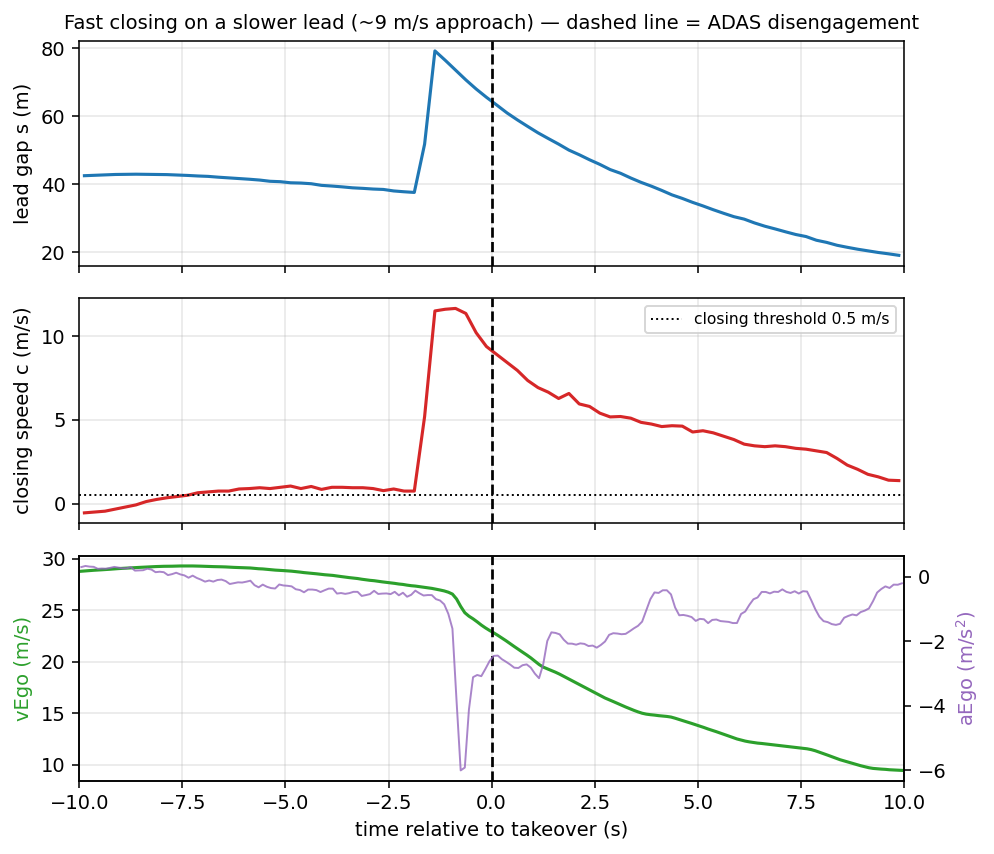
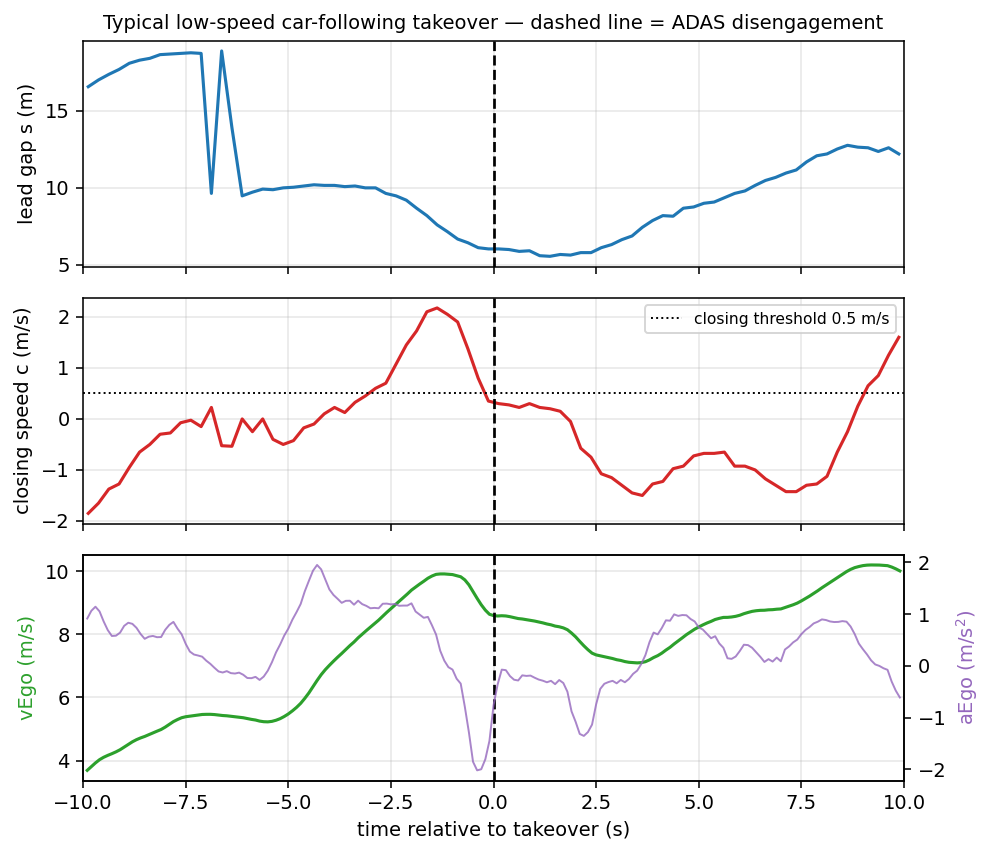
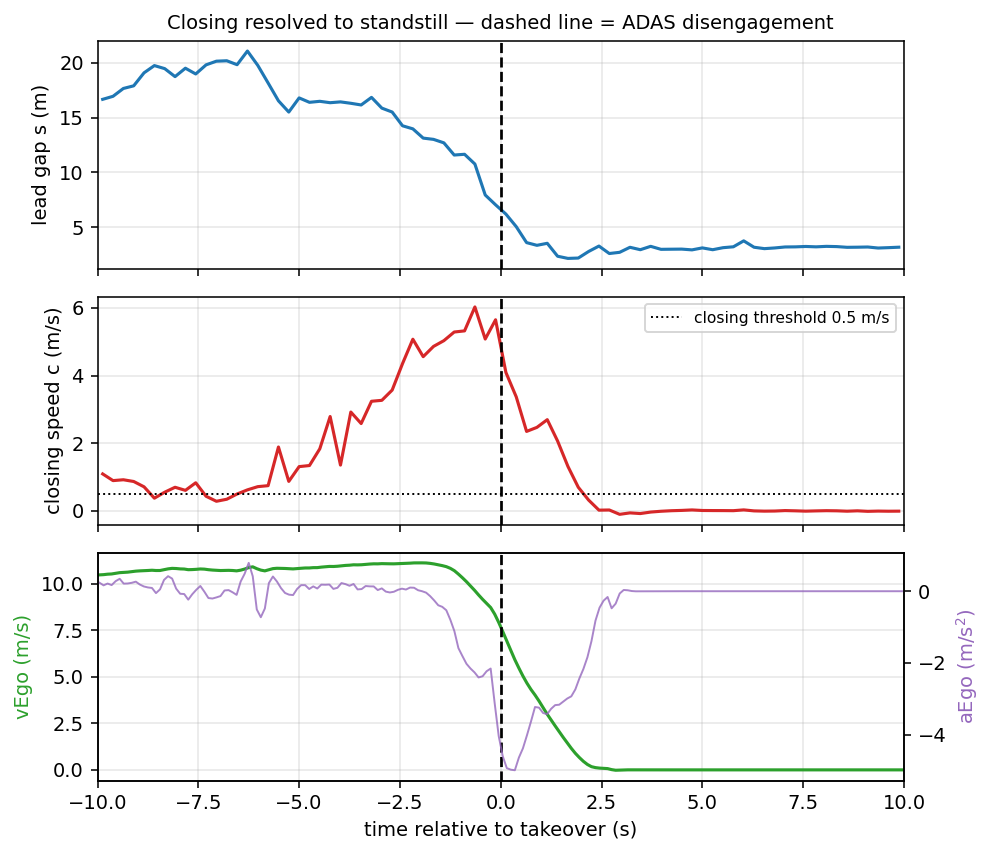
Forward video (red flash = ADAS disengagement, takeover at 10 s) with the synchronized radar/CAN signals of the same clip.
Fast closing on a slower lead (~9 m/s approach) — TOYOTA_PRIUS/driver_142/route_001/0
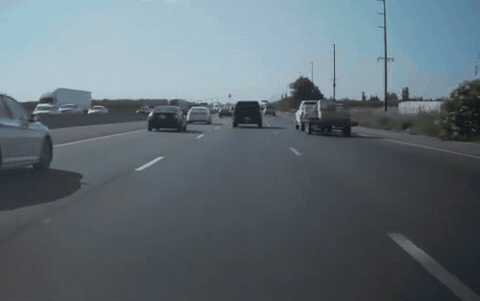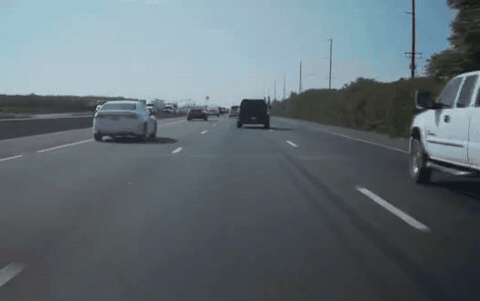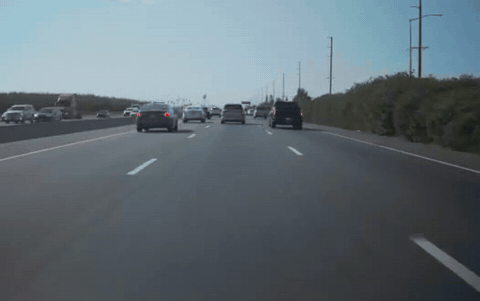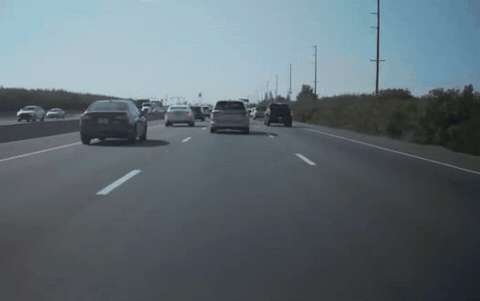
Typical low-speed car-following takeover — TOYOTA_PRIUS/driver_182/route_010/2
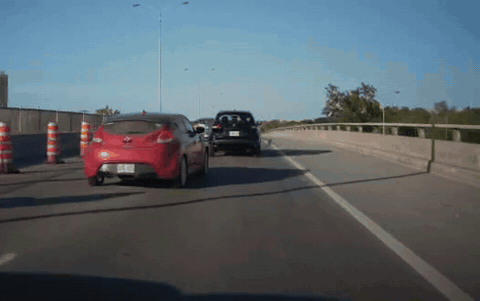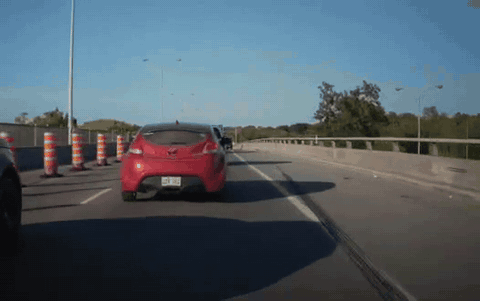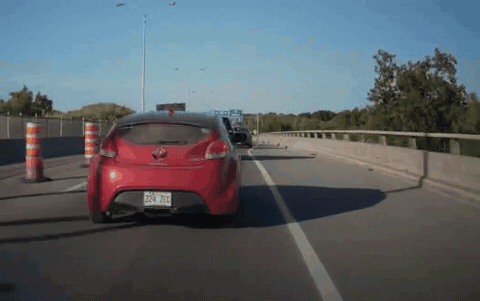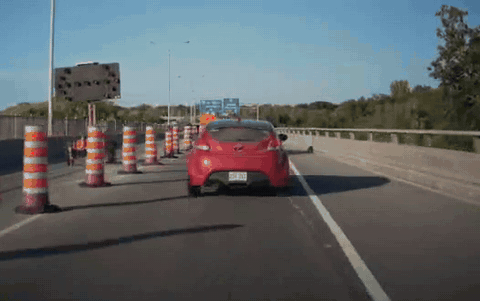
Closing resolved to standstill — VOLKSWAGEN_SHARAN_MK2/driver_289/route_007/1
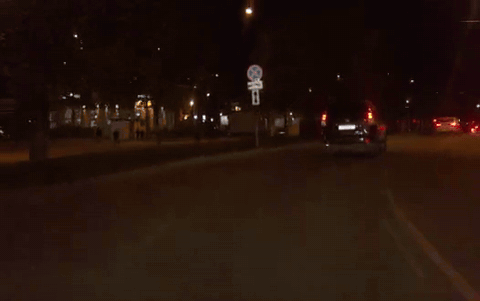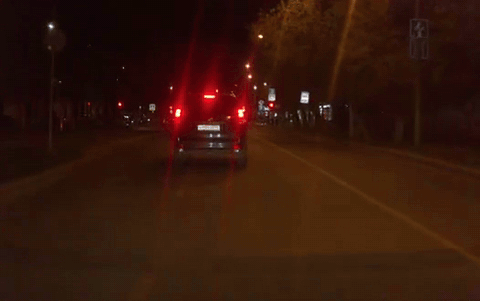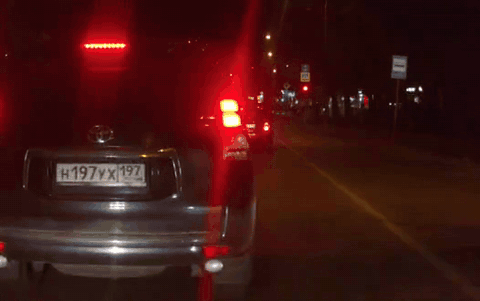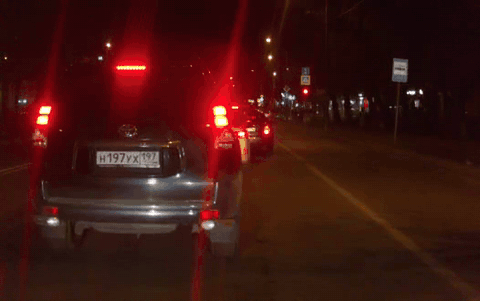
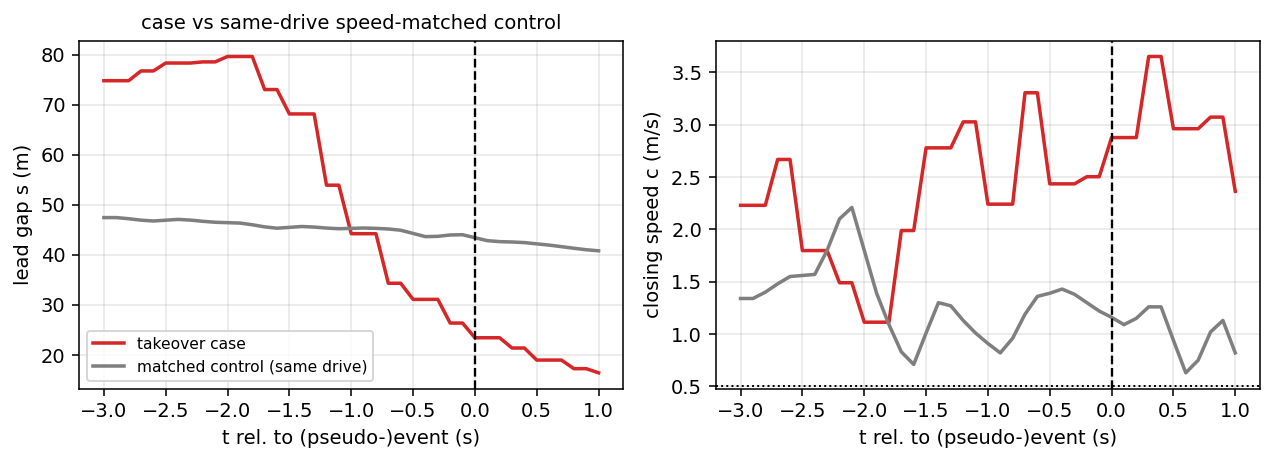
Case vs same-drive matched control — both contain sustained closing; only the case ends in a takeover:
Windows (windows.parquet)
Per window: 41 samples at 10 Hz, t in [-3.0, +1.0] s; t = 0 is the
ADAS disengagement (cases) or the pseudo-event anchor (controls).
| column | description |
|---|---|
| win_id | window id (T_* case / Q_* control) |
| t | time relative to (pseudo-)event, s |
| s | radar lead gap, m (NaN when no valid lead) |
| vr | radar relative speed vRel, m/s (closing speed = -vr) |
| vE | ego speed, m/s |
| aE | ego measured acceleration, m/s^2 (realized vehicle response) |
| valid | lead-valid flag (isfinite(s) & s > 0.5) |
Meta (meta.parquet)
arm (T/Q), anonymized clip (cases; matches the public ADAS-TO release
paths), car_model, anonymized driver/route, window mean ego speed
v_mean, sustained-closing duration sus (s), maxDv/minTTC over the
pre-event closing window, control sub-window offset t0_sub, and the
case-control pairing (has_ctrl, matched_case, match_relaxed).
Clips (clips/)
For each case (arm T) the original 20 s clip is included at
clips/{meta.clip}/: the forward video takeover.mp4 (takeover at
10 s) and 13 openpilot log CSVs (carState, carControl, carOutput,
controlsState, drivingModelData, longitudinalPlan, radarState,
accelerometer, VehicleIMU, Gyroscope, CameraOdometry, LiveCalibration,
LiveParameters) plus a sanitized meta.json (anonymized driver/route
ids). File layout and anonymization follow the main ADAS-TO release.
Controls (arm Q) have no clips by construction — they are unlabeled
engaged stretches of the same drives; their radar/ego series are in
windows.parquet.
Construction
- Cases: all-corpus longitudinal takeovers with radar lead coverage >= 0.9
over video [7, 11] s and a sustained closing episode (approach speed
= 0.5 m/s for >= 1.0 s) inside [7, 10] s (takeover at 10 s).
- Controls: same-drive engaged windows with no driver input and no disengagement, >= 60 s away from every takeover on the route, containing a closing episode under the identical criterion; pseudo-event = episode sub-window start + 3 s; speed-matched (+-5 m/s) per case, K = 2.
- 1,436 cases have same-drive matched controls; 857 have none (kept).
Caveats
- Case-control sampling: model outputs on this set are not absolute naturalistic takeover probabilities.
aEafter driver input may reflect the driver, not the automation.- Radar-missed leads and cut-ins are out of scope by construction.
- Downloads last month
- 37